CovidSim 😷
A covid-19 simulation game (2020)
Covid-19 has taken over the world as we all know (27-06-2020). But even in times like these, we can try to take a different perspective on this and find out what might work to minimize the spread.
While many are working towards building a vaccine which may ultimately fix this problem, I thought we all can experiment on what might work to minimize the spread. The main entity being blamed across the world is the government! So I thought we can all be the governments in this mini-game and modify our country policies to minimize the spread.
The code is highly optimized and scalable over agent population and written using Numba compiler. Hope the video gives a good idea about the different features that I implemented.
Inspired by 3b1b animations
Fall Detection using CNN and RNN 👴
Using sensor data, detect if the user is falling or not (2017-18)
In this repository, I have implemented two fall detection algorithms based on sensor data (accelerometer and gyroscope) to classify the movements of a person as either `fall` or `non-fall`. The implementation is done using Tensorflow's `layers` API. The implementation uses a Convolutional Neural Network / Recurrent Neural Network followed by several dense layers. The final output is a single sigmoid score (1 = fall, 0 = non-fall). A Mean squared error metric is used as the loss function and optimized using AdamOptimizer.
Enjoy the tensorboard video above going through my model.
Semi-autonomous Self-driving Car 🚗
(2017-18)
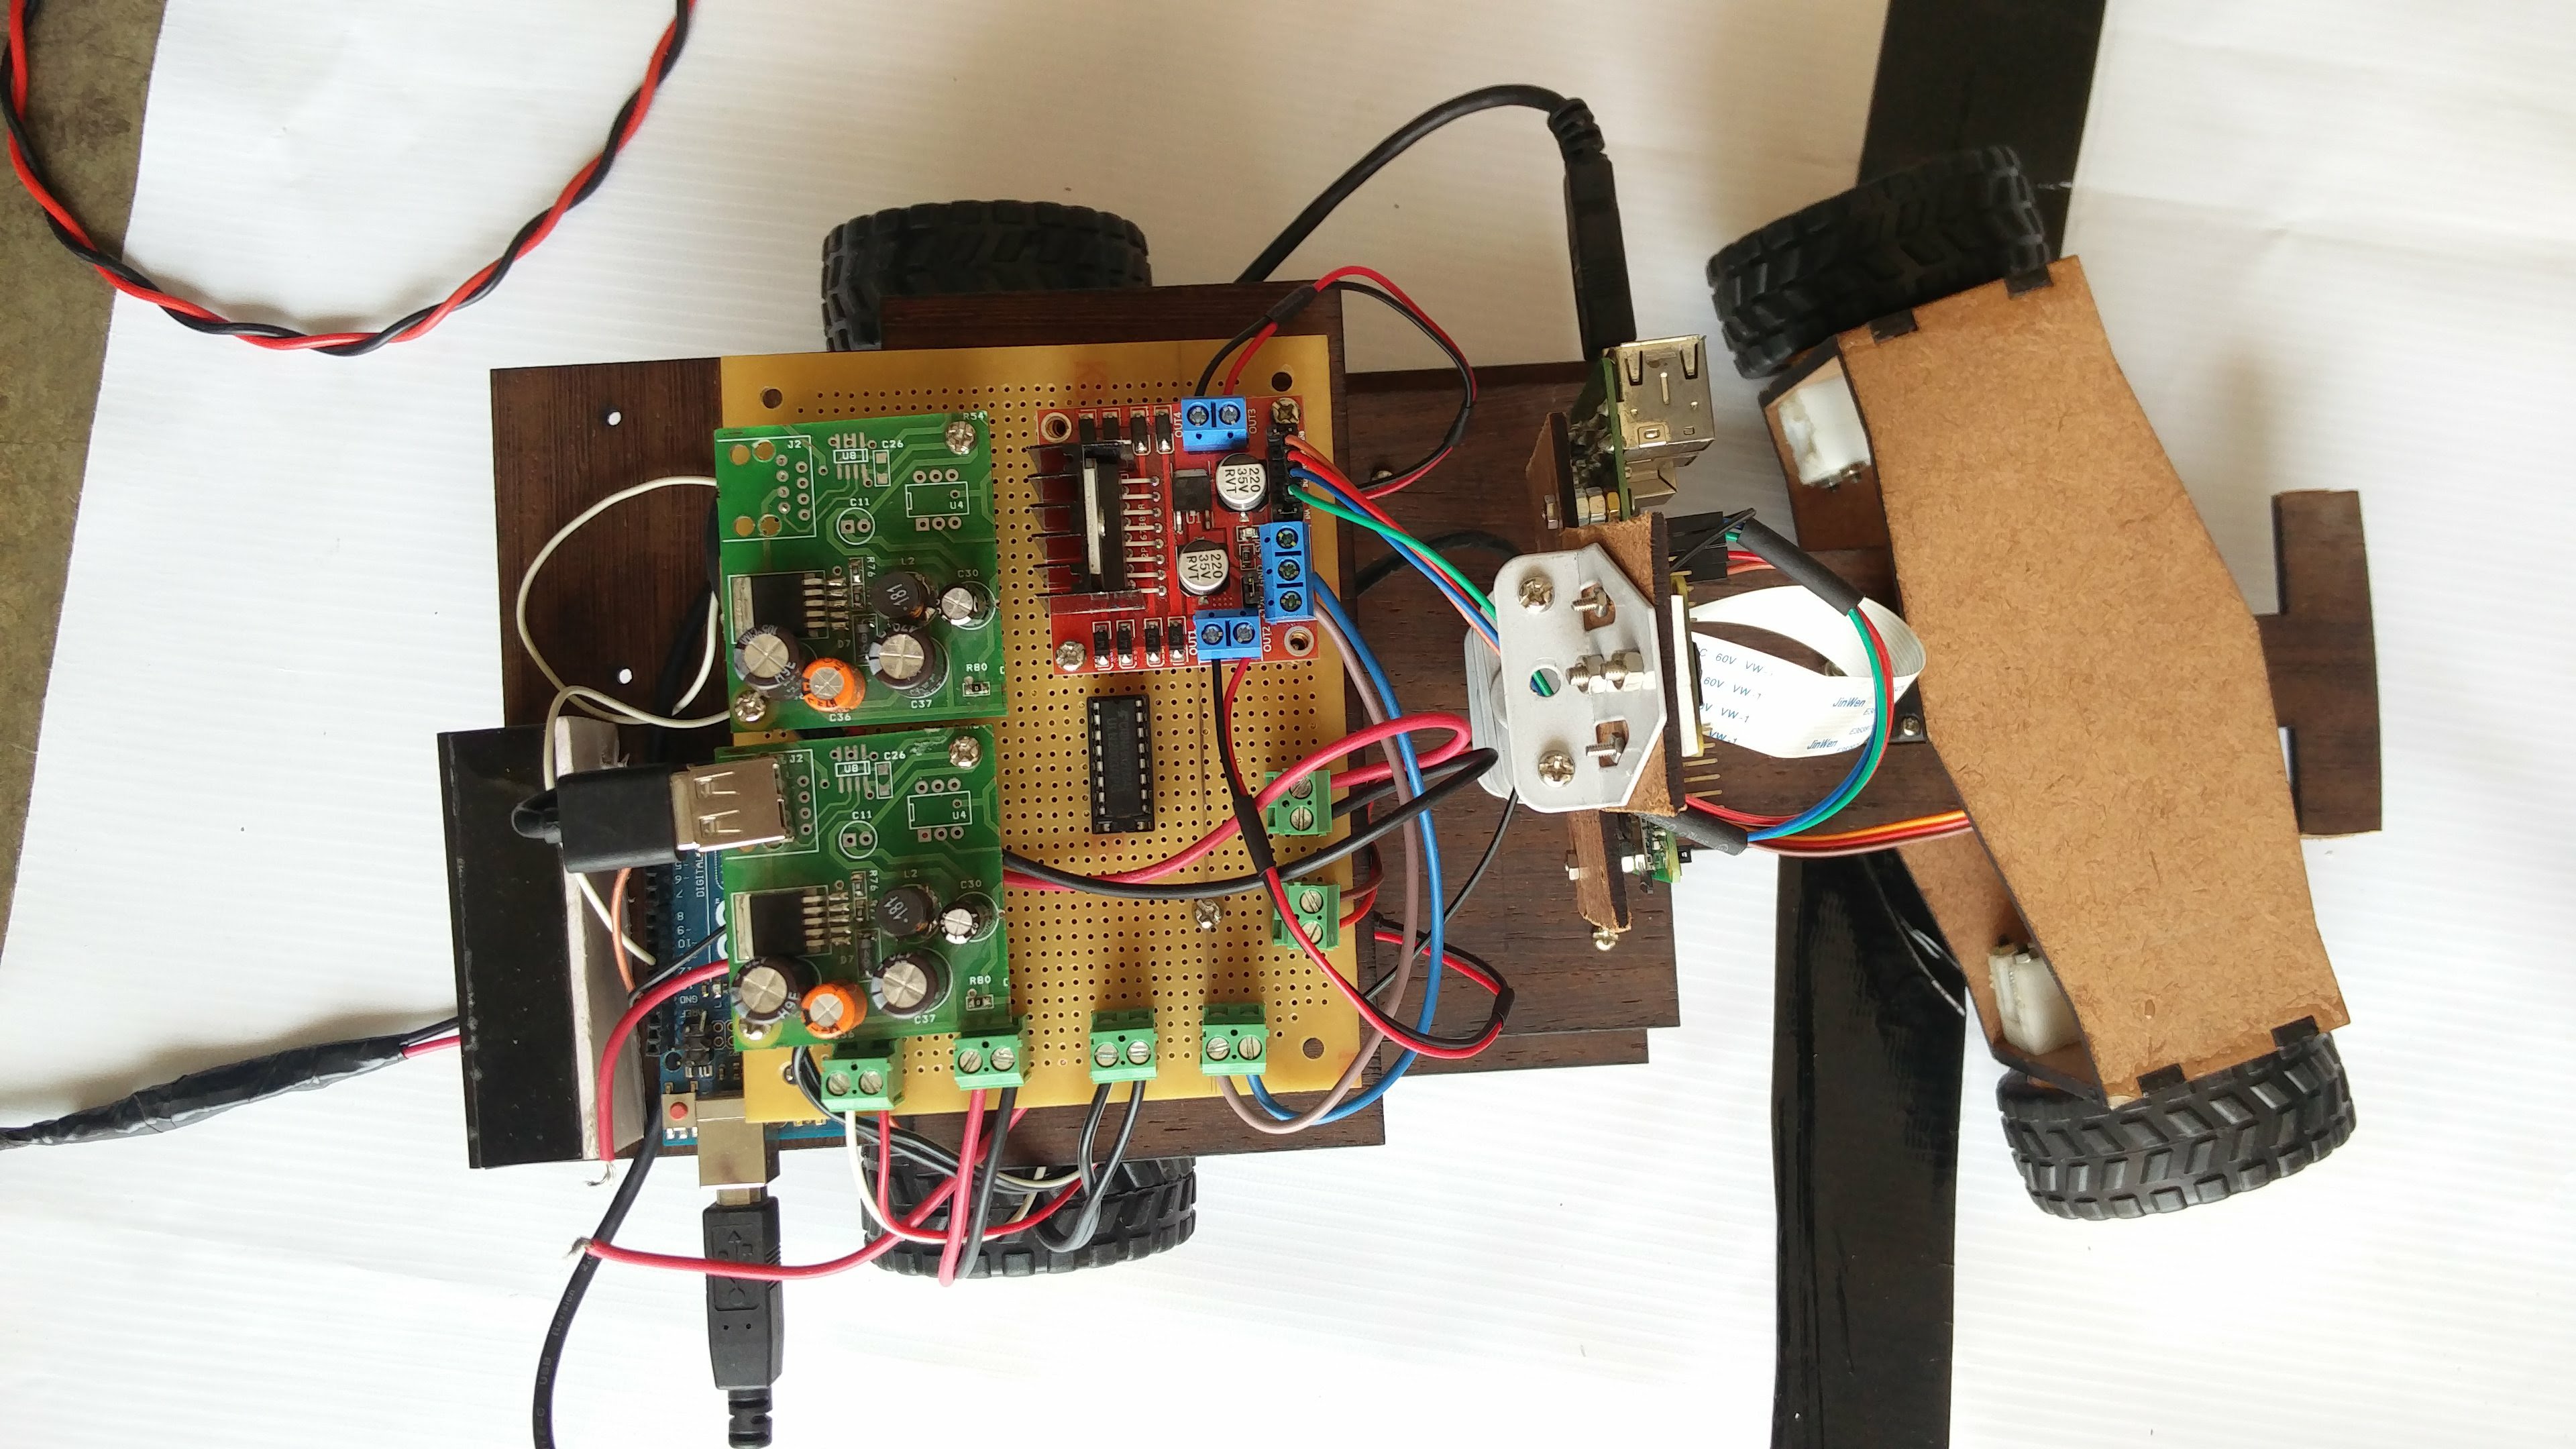
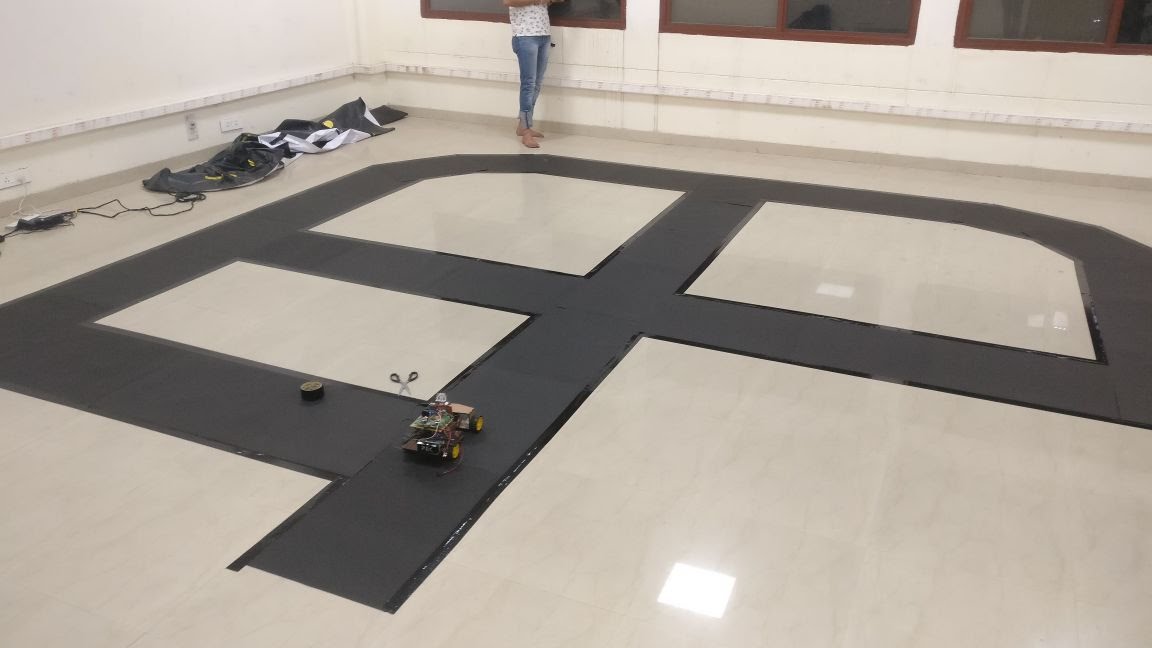
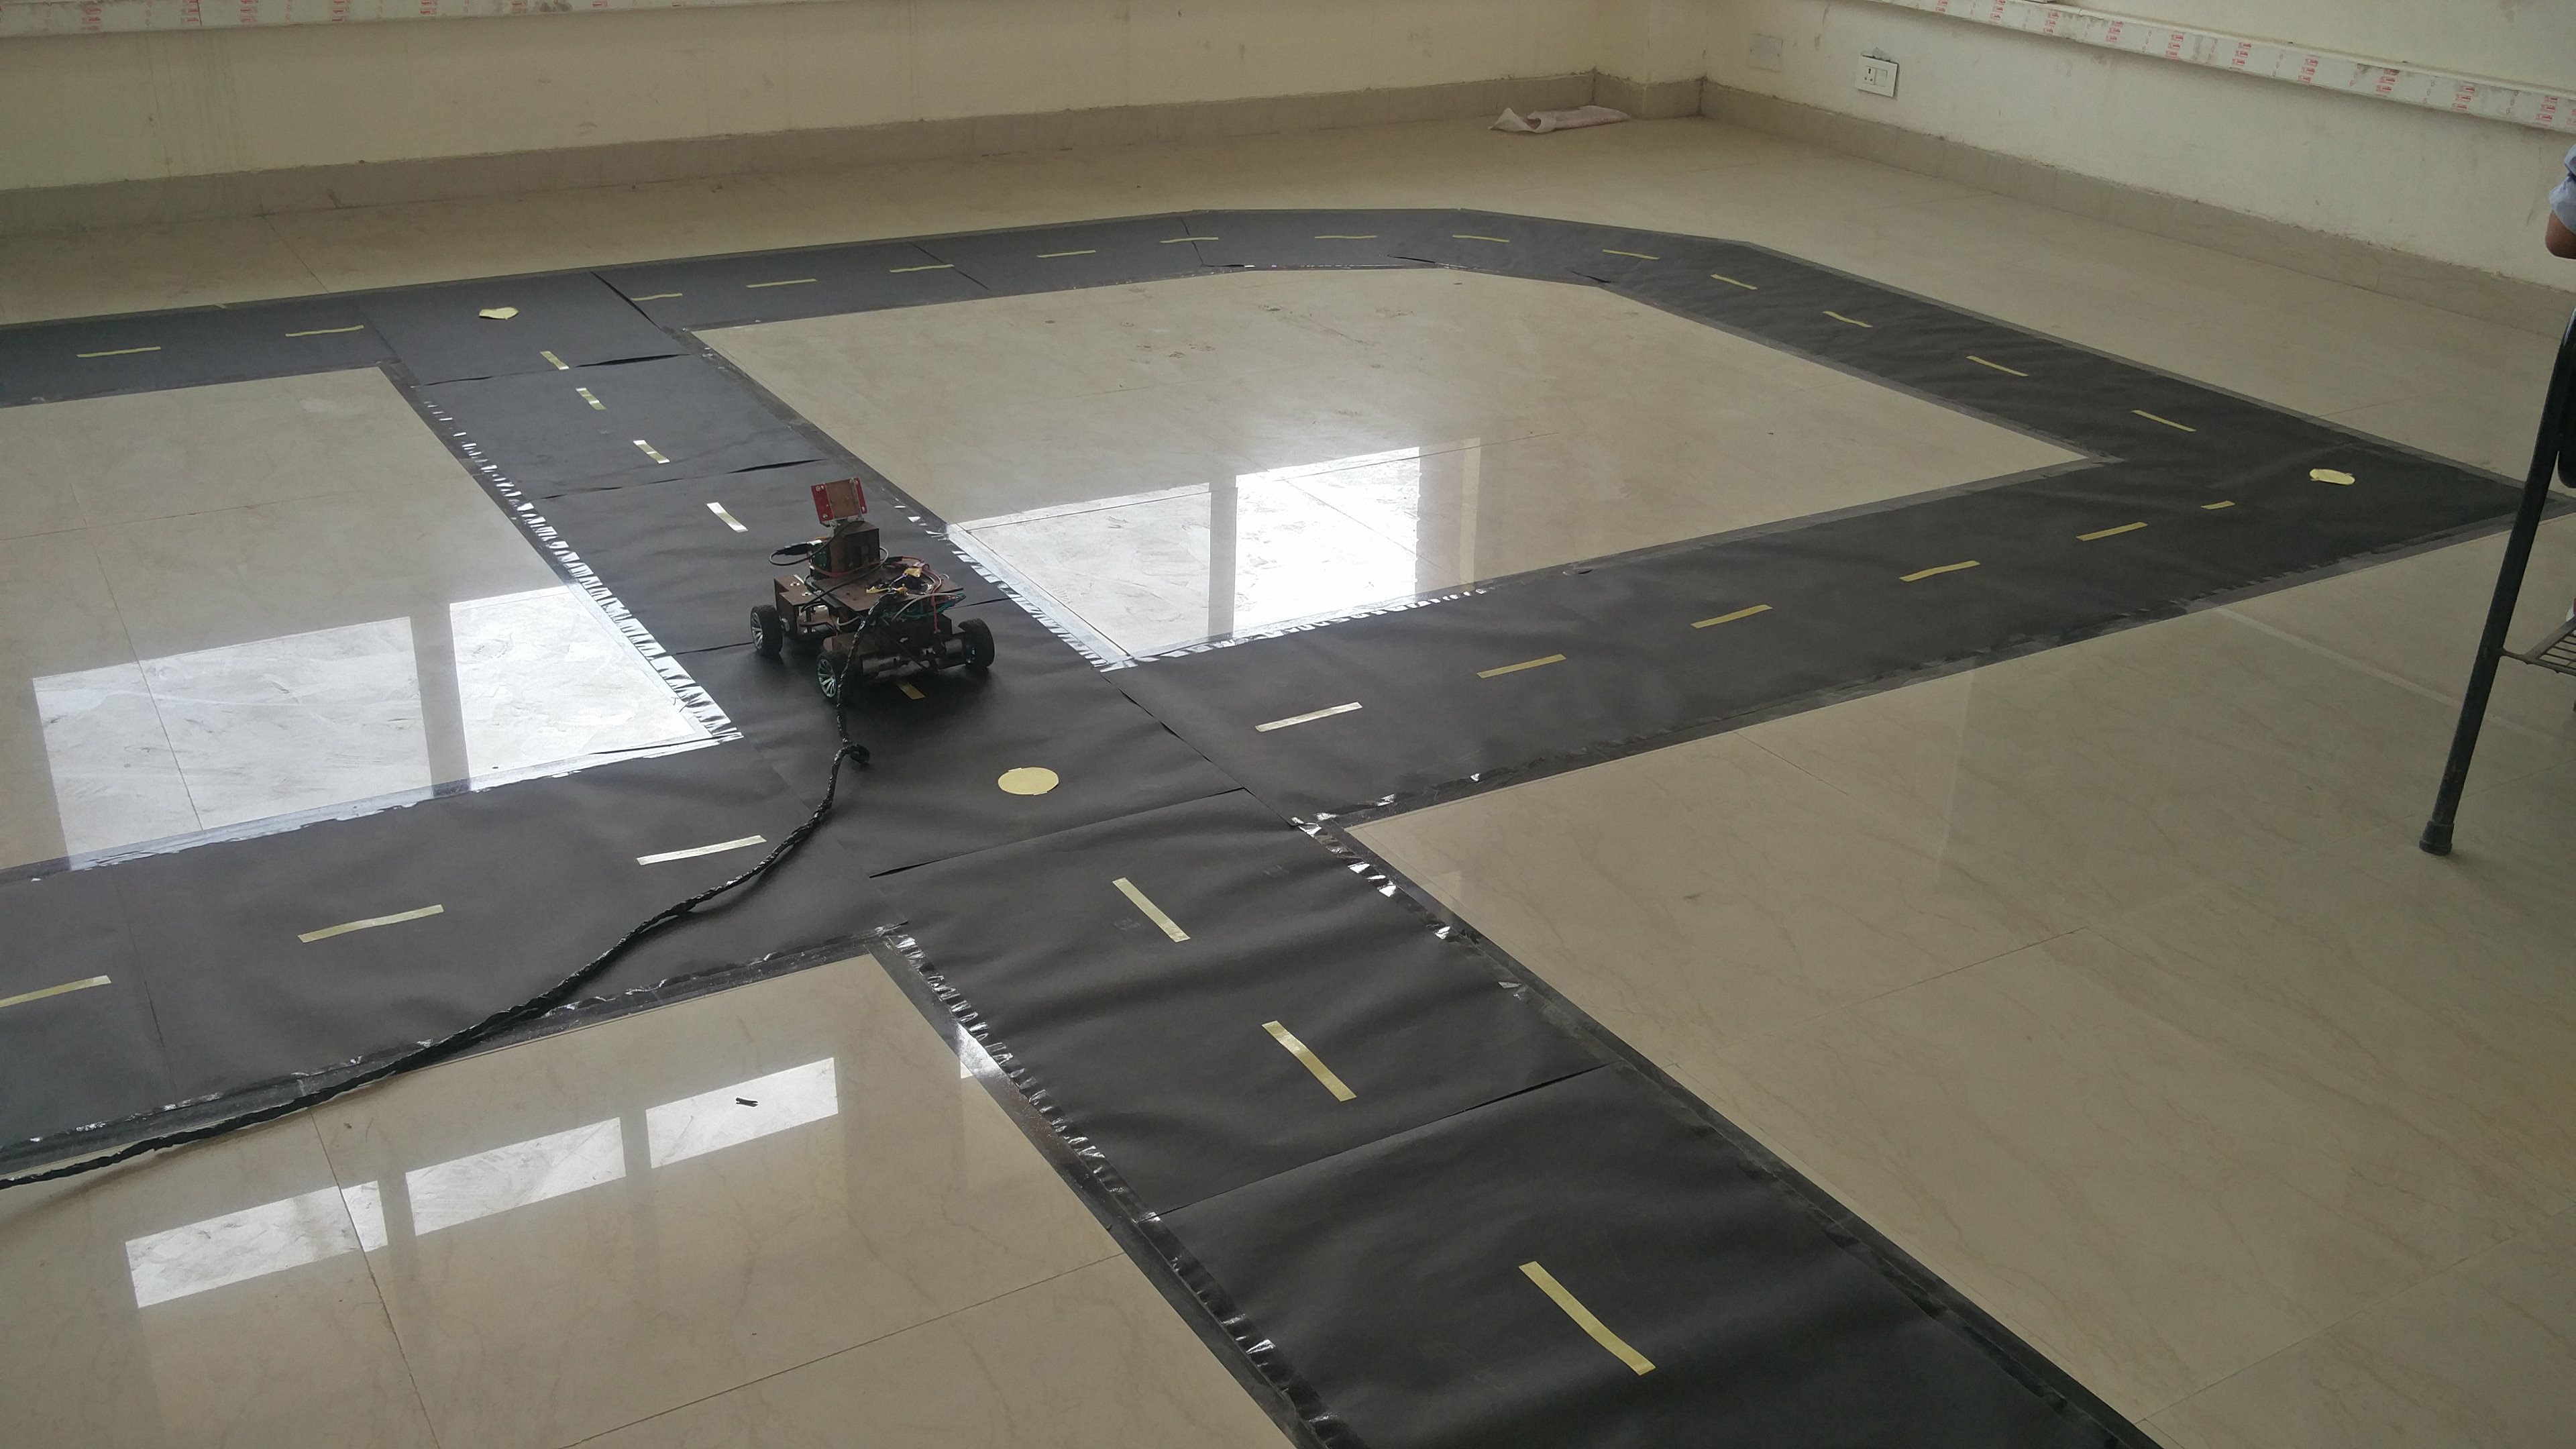
In my final year's capstone project, we created a functinoal semi-autonomous self driving car prototype. We built it from scratch including the car and its chassis as well as the end-to-end Convolutional Neural Network model to turn RGB camera input to steering angle and speed. We also introduced an android app in the middle to convert any voice commands from user to override the default behavior (e.g. user can say 'turn left' which will be read by the system and the car will take left turn on next possible left turn).
The model generalized well on unique track scenarios. A big shout out to my teammates Nikhil Sharma, Gaurav Arora, Harjot Singh, Prince Dhaliwal for their excellent contributions to this project.
Tensorflow | Data Augmentation | Convolutional Neural Networks | Speech-to-text (Android built-in) | Arduino | Circuit and power design
P.S. this is not a line-follower. The car decides steering angle and speed based on RGB input (using neural network model).Below are some glimpses of our work (it was a long and tiring project (collecting training data was very time consuming) so we were not able to document it upto the level we expected, but hope this gives a picture of the work we did). We also implemented red-light stop sign training.